| Technical Name | Construction Automation: AI-Driven On-Site Construction Robotics | ||
|---|---|---|---|
| Project Operator | Feng Chia University | ||
| Project Host | 盛郁庭、顏貽祥、王識源 | ||
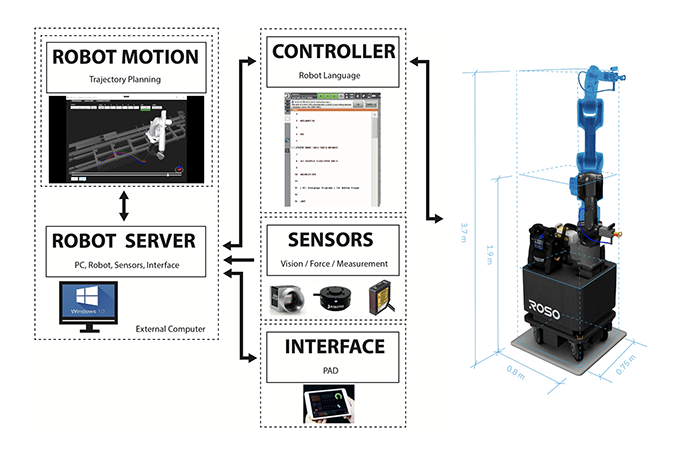
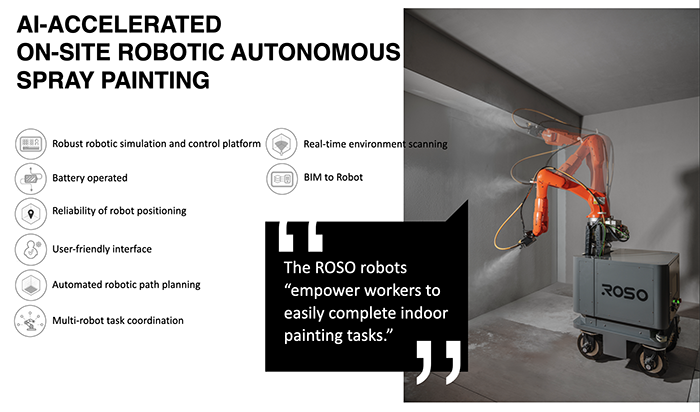
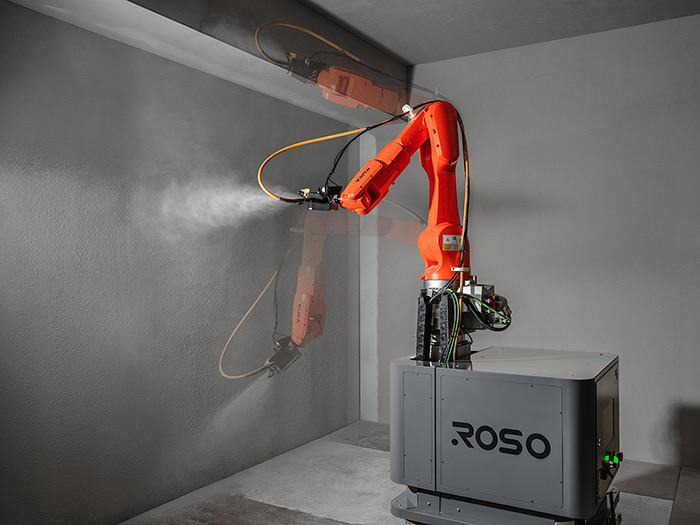
| Summary | The ROSO AI On-Site Construction Robot integrates a robotic arm, an autonomous mobile robot (AMR), AI-powered computer vision, and multisensor fusion to create an intelligent construction system capable of autonomous navigation, spatial localization, scene recognition, and human–robot collaboration. Designed for complex construction environments, the system enables real-time obstacle avoidance, construction-site analysis, and automated operations, improving productivity, quality consistency, and the implementation of smart construction. |
||
| Scientific Breakthrough | This technology overcomes the limitations of conventional robots and AMRs, which are typically restricted to predefined paths and highly controlled environments. It enables autonomous operation in dynamic and unpredictable construction sites. By integrating AI-powered computer vision, SLAM, multisensor fusion, and semantic understanding, the system achieves spatial perception, autonomous navigation, dynamic obstacle avoidance, and human–robot collaboration—advancing construction robotics from conventional automation toward intelligent and autonomous operation. |
||
| Industrial Applicability | This technology is designed for labor-intensive and repetitive indoor construction tasks. By deploying AI-driven on-site construction robots, it improves productivity while reducing occupational safety risks and physical demands on workers. Real construction sites also provide valuable operating environments in which robots can accumulate real-world data and human–robot collaboration experience. This process strengthens their spatial perception, autonomous decision-making, and motion-control capabilities, laying the foundation for future physical AI and autonomous construction applications. |
||
- Contact
- Yu-Ting Sheng
- shengdigiarchi@gmail.com
other people also saw